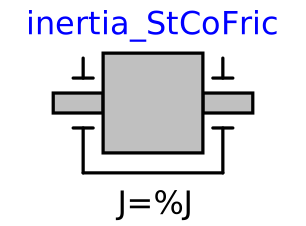
modelinertia_StCoFric
Inertia with frictional torque (Coulomb and Stribeck friction), modelled with finite state
Information
Version 1.6
Last modified 11.07.2011
Rotational component with inertia, frictional torque, and two rigidly connected flanges.
The concept is based on the mass with friction model which comes with standard Modelica Library.
The frictional torque is made up of Coulomb and Stribeck friction. Viscous friction is neglected for the time being.
Finite state model is used to model the frictional torque of inertia.
V1.6 Viscous friction is added to the model.
Parameters
| Type | Name | Default | Description |
|---|
| SI.Torque | M_coulomb | 3e-4 | Coulomb friction torque (1.3e-4) |
| SI.Torque | M_stribeck | 6e-4 | Stribeck friction torque (7e-5) |
| Real | R_prop | 1e-4 | Viscous friction coefficient |
| SI.Inertia | J | 1.09e-7 | Moment of inertia |
| Real | fexp | 1 | Exponential decay |
| Integer | stuck | 0 | if w_rel=0 and not sliding |
| Integer | startforward | 1 | begin of forward movement |
| Integer | forward | 2 | forward movement |
| Integer | startbackward | -1 | begin of backward movement |
| Integer | backward | -2 | backward movement |
| Advanced |
| StateSelect | stateSelect | StateSelect.default | Priority to use phi and w as states |
Components
| Type | Name | Default | Description |
|---|
| SI.Angle | phi | | Absolute rotation angle of component |
| SI.AngularVelocity | w | | Absolute angular velocity of component (= der(phi)) |
| SI.AngularAcceleration | a | | Absolute angular acceleration of component (= der(w)) |
| SI.Torque | M_tau | | auxiliary variable for driving torque |
| SI.Torque | tau_fric | | |
| SI.Torque | M_fric | | sum of Coulomb and stribeck friction |
| Real | sa | | Path parameter of friction characteristic tau = tau(a_relfric) |
| Integer | mode | | |